AGV Motor Sizing Checker for 24V/48V Robotics
Screen AGV motors for robotics: estimate torque, current and voltage headroom for 24V/48V drivetrains. Carry the assumptions into an RFQ, then validate with supplier curves and a vehicle pilot.
Published - Last updated
Executive summary for AGV motor decisions
Core conclusions, key numbers, and applicability boundaries in one screen before deeper section review. All numeric fit bands are internal screening prompts, not validated motor, controller, or temperature ratings.
Applicable for
- Indoor logistics routes with known floor profile and grade map.
- Teams that can run pilot instrumentation before final lock.
- Programs comparing 24V against 48V with clear TCO criteria.
Not applicable for
- Unmeasured outdoor routes with large traction uncertainty.
- Safety-critical final approval without supplier test evidence.
- Projects that require public benchmark proof for every duty map.
Evidence updates and decision boundaries
Recommendations are tied to sources, applicable conditions, and counter-examples. Where public mission data is incomplete, use a supplier review and a representative vehicle pilot.
| Conclusion | Applies when | Limit / counter-example | Source tag | Updated |
|---|---|---|---|---|
| Use ISO 3691-4 primarily for driverless truck safety scope and misuse boundaries. | Deployment scoping, hazard review, and route-operating-zone preparation. | Not for power-source requirements; severe conditions (freezer/public road/explosive zones) need extra controls; official page lists a draft successor under development. | S1 | 2026-11-02 |
| Normalize supplier duty terminology to IEC 60034-1:2026 before RFQ comparison. | Comparing continuous/peak claims across motor vendors and controller stacks. | Legacy sheets may still cite IEC 60034-1:2022 (withdrawn on 2026-03-13). | S2, S3 | 2026-11-02 |
| Use IEC 61800-9-2 system-level indicators for efficiency comparisons. | 24V versus 48V architecture screening where controller + motor losses both matter. | Full clause text is paywalled; final compliance interpretation requires purchased standards. | S4 | 2026-11-02 |
| Workplace conditions (surface, ramps, hazardous areas) must be part of operational readiness. | Facilities where AGV routes overlap PIT-style operating constraints. | OSHA citation is U.S.-specific; use local legal framework in other jurisdictions. | S5 | 2026-11-02 |
| Freeze fleet-interface protocol version in RFQ/FAT to reduce integration surprises. | Projects integrating mobile robots and central fleet-control systems. | Public protocol release does not guarantee backward compatibility for your stack. | S6, S7 | 2026-11-02 |
| Keep calculated continuous load inside supplier T_cont and request peak/stall margin evidence before using a 3x target. | General sizing for AGVs before specific vendor testing. | The 3x target is a screening heuristic, not a universal standard; duty cycles deviating from S1 (e.g. S2 or S3) may require custom thermal simulations rather than fixed ratios. | S9 (explicitly uncertain) | 2026-11-02 |
| Do not select brushed DC without a documented brush/commutator inspection plan. | Legacy AGV retrofits or high-uptime lines. | BLDC removes brush wear but still needs bearing-life and thermal validation from supplier data. | S10 | 2026-11-02 |
| Request winding and magnet temperature limits; the thermal screening index cannot predict either temperature. | Continuous heavy-grade or high stop-start routes. | N/SH/UH magnet classes are reference points; final safe temperature depends on B-H curve limits against stator currents. | S11 | 2026-11-02 |
| Migrate legacy 200W 24V DC designs (e.g., Oriental Motor BLV620K30S-1) to current-generation replacement families (e.g., BLV Series R Type) to avoid obsolete-part procurement. | Legacy AGV retrofits and BOM updates for 200W-class drive platforms. | Direct drop-in mechanical, driver, interface, and mounting compatibility must be verified against the current supplier datasheet. | S12, S13 | 2026-11-02 |
| Do not mandate IEC 60034-30-1:2025 IE classes for battery-operated 24V/48V AGV drive modules; use them only as efficiency benchmarks. | Evaluating BLDC efficiency claims for AGV battery runtime. | Line-operated motors within the 2025 scope can be compared under this standard; integrated compact drives and low-voltage mobile drive modules need drive-system evidence instead. | S14 | 2026-11-02 |
| Evaluate drive/controller Safe Torque Off (STO) evidence per IEC 61800-5-2 when the AGV safety architecture relies on controller-level torque prevention. | New AGV/AMR designs with integrated motor drives, E-stop recovery requirements, or safety functions assigned to the drive controller. | STO is not a motor sizing metric and does not replace the full ISO 3691-4 risk assessment; some legacy or low-risk architectures may use other validated torque-removal methods. | S1, S15 | 2026-11-02 |
| For low-speed smoothness, evaluate the actual motor winding and controller commutation together; do not infer torque ripple from a PMSM/BLDC label alone. | Applications with defined low-speed torque-ripple, vibration, or acoustic limits. | TI reports control-method tradeoffs: trapezoidal control is simpler, while sinusoidal/FOC behavior depends on motor BEMF and the selected drive. Validate the motor/controller pair at the required load and speed. | S16 | 2026-11-02 |
| Set encoder resolution from required wheel-distance counts, reduction ratio, and maximum speed; verify the selected device against the actual environment. | AGV odometry and motor-feedback designs where counts per wheel revolution and environmental limits affect performance. | There is no universal PPR or optical/magnetic cutoff. Renishaw documents contamination tolerance for one optical encoder system; check the exact encoder specification and validate on-route. | S17 | 2026-11-02 |
| Compare reducer models using specified backlash, torsional stiffness, rated/peak torque, radial load, and life at the target duty. | Heavy-duty routes and precision docking, where reducer limits affect the vehicle-level result. | The Nabtesco RV guide gives model-specific data for a compound reducer; those figures do not establish a universal cycloidal-versus-planetary ranking. Compare candidate data at matched conditions. | S18 | 2026-11-02 |
| Separate robotics traction screening from safety, braking and controller integration approval. | Battery-driven AGV / AMR motor and controller RFQ review. | No universal overload ratio, network rate or safety encoder topology is established. STO does not brake or isolate. Validate the selected system. | S1, S15, S19, S20, S21 | 2026-11-02 |
| For multi-motor drivetrains, size the DC traction bus for simultaneous peak current summation and dynamic regenerative braking energy clamping. | Dual-drive differential AGVs, quad Mecanum platforms, and multi-axis robotics vehicles. | Battery charge acceptance depends on pack, SoC, temperature and BMS. Validate the available energy path; a compatible braking chopper/resistor is one option when required by the selected drive design (S25). | S9 (current-balance method), S25 (regeneration) | 2026-11-02 |
Boundary table: when to trust and when to stop
This boundary layer prevents over-confidence in nominal labels and gives minimum fallback actions.
| Condition | Threshold | Risk if ignored | Minimum action |
|---|---|---|---|
| Torque-derived motor current proxy crosses a review trigger | > 80A (review), > 120A (redesign); heuristic only | The proxy may not match the supplier motor-phase or controller DC-bus current convention. | Compare supplier peak/RMS motor current with controller phase and bus ratings under the same duty conditions. |
| Voltage utilization near saturation | > 82% (review), > 92% (redesign) | Back-EMF headroom collapse at speed and torque fade. | Lower Kv, reduce target speed, or evaluate 48V architecture. |
| Thermal load index above sustained envelope | > 8.0 (review), > 12.0 (redesign) | The index is not a winding or magnet temperature and can miss a real thermal limit or reject a viable motor. | Request supplier thermal data and instrument a representative pilot at worst-case ambient and duty. |
| Route grade and floor shock combined stress | grade >= 8% with rough floor | Wheel slip and torque spikes beyond nominal datasheet claims. | Pilot on real route and collect slip/current events. |
| Gear ratio too low for payload-speed pair | < 10 in heavy duty profile | Continuous high motor current and low efficiency region operation. | Increase gear ratio or reduce required top speed. |
| Harsh environment with fluid or dust exposure | Cleaning protocols require IP65 or IP69K | Premature bearing failure or electrical short in non-sealed standard indoor motors. | Specify IP65/IP69K motor housing and sealed connectors in the RFQ. |
Reproduce this AGV motor screening result
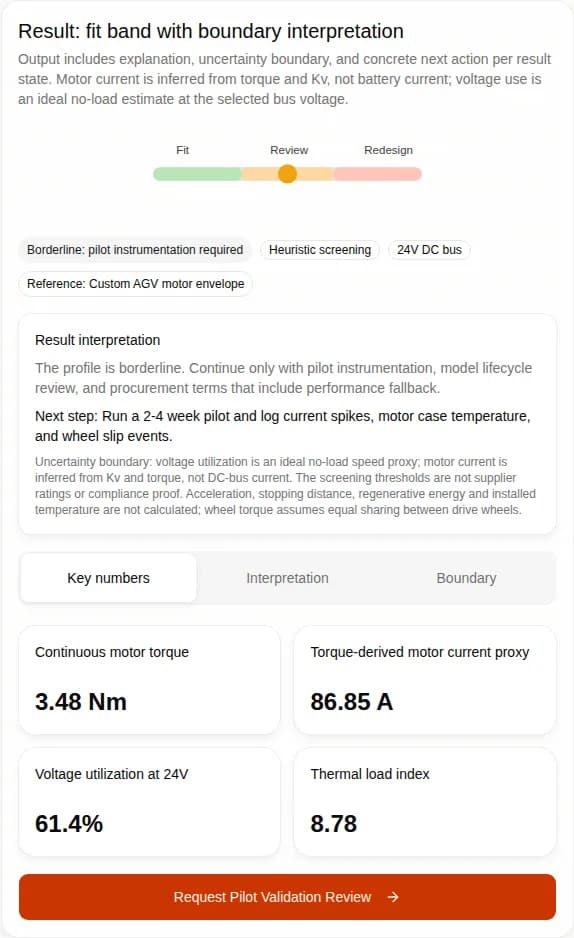
Captured 2026-10-24 from this calculator, using 1200 kg moving mass, 200 mm wheels, 2 driven wheels, 1.2 m/s, 4% grade, coated concrete, 16 h/day, 10 stops/min, 18:1 gearing, 1.25 safety factor, Kv 140 rpm/V, outer-rotor motor and 24V nominal bus.
Select the custom profile and reset the default inputs to reproduce 3.48 Nm, 86.85 A and 61.4% voltage utilization. The result is a borderline screening case requiring pilot instrumentation. The current proxy is not DC-bus current.
This is software execution evidence, not a measured motor test, supplier endorsement or customer case study. The image contains the result panel through its action button; unused panel space and site navigation are outside the crop, and the floating WhatsApp control is hidden for this illustration.
Method published by AGV Drive Wheel (AGV Drive Wheel). Request supplier curves and a vehicle pilot before approval.
Review your motor sizing assumptionsAGV motors for robotics: mobile platform drivetrain architecture and sizing
Engineering specifications, fieldbus control standards, and power-train trade-offs for autonomous mobile robots (AMRs) and automated guided vehicles (AGVs) operating in dynamic industrial environments.
Battery → drive → wheel
- Confirm loaded battery voltage
- Check peak torque and duration
- Plan a verified regen energy path
Host → controller → feedback
- Verify supported network modes
- Assess safety functions separately
- STO alone does not brake or isolate
Motor → mount → chassis
- Confirm installed cooling limits
- Measure temperature during duty
- Validate floor shocks and ingress
Design checklist, not a certified safety circuit. Sources: S1, S15, S19, S20.
Kinematic & Torque Dynamics for Mobile Robotics
AGV motors for robotics drive vehicle wheels; robot arm servos need a separate joint-inertia and gravity model. This tool screens 24V/48V traction using rolling resistance, grade and disclosed stop-start heuristics. It does not solve acceleration, braking distance, wheel slip or regenerative energy. No universal peak-to-continuous ratio is established here; obtain the motor and controller torque-time curves.
- Differential vs. Steer-Drive: Two-wheel differential drive AMRs use independently speed-controlled outer-rotor or inner-rotor BLDCs with planetary gears, while steer-drive platforms decouple traction and azimuth rotation.
- Regenerative Braking Absorption: Plan an energy path with the drive and battery suppliers. Battery charging capability and a brake resistor are possible design inputs, not interchangeable guarantees. Verify full-charge BMS limits, DC-bus overvoltage and stopping behavior in the vehicle pilot.
- Thermal Baseplate Conduction: Chassis conduction is one cooling option. Allowable load depends on the actual mounting, airflow, ambient and motor thermal data. The tool’s thermal index predicts neither winding nor magnet temperature; no universal temperature or 70% load cutoff applies.
Safety Standards & Autonomous Fieldbus Integration
ISO 3691-4:2023 covers driverless industrial truck safety (S1); ANSI/ITSDF B56.5-2024 covers relevant driverless guided vehicle systems (S21). Confirm applicability, edition and required safety functions with the project compliance owner. Public scope pages do not establish a universal encoder architecture or a blanket PL d / SIL 2 target.
- Safety-related feedback: If the safety design uses SLS or SDI, validate the complete feedback, logic and drive subsystem against its assigned performance target. Two encoder channels alone do not establish safety certification (S1, S15).
- Safe Torque Off (STO): STO prevents torque-producing energy; a moving motor can coast. It does not provide controlled braking, grade holding or electrical isolation. Validate stopping distance, brake sequencing and response time independently (S15, S20).
- Deterministic Fieldbus (CANopen CiA 402 / EtherCAT): CiA 402 defines drive behavior and modes, but devices can implement different subsets (S19). Verify PDO mapping, watchdogs, supported modes and the ROS 2 host bridge. Select update rates from measured latency and vehicle dynamics; a fieldbus label does not guarantee docking accuracy.
AMR example: what the screen leaves open
Case D assumes 650 kg moving at 1.6 m/s. Translational kinetic energy is ½ × 650 × 1.6² = 832 J. A stop in 1 second gives an average translational energy rate of 832 W before drivetrain losses; rotating inertia and downhill travel can add energy. This is an illustrative physics calculation, not a resistor rating or an emergency-stop prediction. Ask suppliers to confirm the energy destination and validate the stop with a fully charged battery.
Comparison below: application-dependent checks, not universal specifications. Exact overload, cooling limits, safety targets and network timing remain pending supplier and vehicle data. Sources checked 2026-10-24: S1, S15, S19–S21. Public standard summaries support scope only; clause-level compliance requires the full standard and a documented assessment.
| Application Category | Bus Voltage | Torque & Overload Margin | Feedback & Safety Standard | Fieldbus / Autonomy Interface | Thermal & Enclosure |
|---|---|---|---|---|---|
| AMR / AGV traction | 24V / 48V examples supported by this tool; confirm full battery range | Calculate wheel torque and acceleration demand; peak duration and rating require supplier data | Select feedback and safety functions from the vehicle risk assessment (S1, S15) | CANopen CiA 402 is one option; verify supported modes, PDOs and host integration (S19) | Confirm installed cooling, ambient and enclosure requirements with the supplier |
| Forklift AGV traction | Vehicle-specific pack; voltages beyond 24V / 48V are outside this tool | Size travel separately from mast lifting; verify grade holding and axle loads | Validate travel stopping and load-holding systems separately (S1, S21) | Match the vehicle controller interface and any separate safety communication | Verify thermal duty, shock loads and ingress protection on the actual vehicle |
| Articulated robot arm joint | Drive-specific; neither a universal mains voltage nor this tool’s traction scope | Requires joint inertia, gravity, acceleration and reducer stiffness calculations | Joint position, holding brake and safety architecture need a separate assessment | Select the servo network and supported modes for the arm controller | Check joint mounting and ambient limits; no universal cooling or IP rating |
| Fixed conveyor / sorter | AC or DC according to the selected conveyor drive | Check belt friction, starting load, jams and duty; no universal overload multiplier | Choose feedback and stop functions from the machine application | Discrete I/O or network control according to timing and diagnostics needs | Verify the exact motor cooling arrangement and installation requirements |
AGV motors: coordinate drive, power and braking
Multi-motor coordination architectures, CiA 402 multi-axis fieldbus synchronization, DC bus peak power summation, and comparative evaluation across motor technologies for AGVs and AMRs.
Autonomy & Coordination Layer
Planner → drive-specific timing checks
- Kinematic setpoint decomposition: v, ω → v_L, v_R
- Verify supported network modes and actual latency
- Validate update timing, wheel feedback and slip
Dual-Axis Power & Safety Controller
Inverters, STO & Regenerative Clamping
- Verify axis mapping in the selected drive manual
- Safety functions and targets from risk assessment
- Validate battery or compatible braking energy path
Physical Traction Drivetrain
Dual Drive Wheels & Ground Kinematics
- Independent PMSM/BLDC motors with planetary gearboxes
- Verify drive-wheel contact and axle load sharing
- Test coordinated stopping and brake fault response
Illustrative multi-motor architecture; verify actual integration. Sources: S1, S16, S19, S22, S25, S24.
Differential motion and integration checks
For ideal no-slip differential motion, vL = v − ωW/2 and vR = v + ωW/2, where W is drive-wheel track width. A measured wheel-speed difference produces yaw rate (vR − vL)/W; timing synchronization alone does not correct wheel-radius error or slip.
- CiA 402 specifies drive behavior and operating modes, but supported functions vary (S19). Confirm mode support, axis object mapping, PDO updates and timeout response in the actual EDS/ESI and manual. No universal 500 µs jitter requirement is claimed.
- Keep adequate normal load on each drive wheel across the route. Determine suspension or chassis compliance from axle loads and floor transitions; no fixed travel requirement follows from the drive layout.
- Measure turn demand with the actual tire, caster and support geometry. The straight-line checker omits steering scrub, unequal wheel loading and traction limits.
DC bus, regeneration and stopping checks
Use separate electrical-load and vehicle-safety reviews. S22 is an electrical scope reference with exclusions; S1 and S24 do not establish a universal brake topology from public summaries.
- Current balance: I_bus(t) = Σ I_DC,drive(t) + I_aux(t). Do not sum motor phase-current proxies as battery current. As a separate illustrative power calculation, two motors delivering 400 W shaft power each at 48 V and assumed 85% combined motor/drive efficiency draw about 19.6 A before auxiliaries. If shaft power is 2.5× at the same efficiency and voltage, the estimate is 49.0 A. A torque overload ratio alone cannot determine power or battery current (S9: internal calculation).
- Regeneration: Confirm pack charge acceptance across SoC and temperature, BMS disconnect behavior and drive voltage limits. A compatible braking chopper/resistor is one possible path when battery absorption is unavailable; follow the selected drive’s limits and validate faults (S25). A resistor does not replace independent stopping and holding functions.
- Asymmetric braking: Unequal wheel forces can generate yaw. Assess coordinated stopping, brake timing, single-drive faults and grade holding. Define required functions and performance levels using the complete assessment; no claim is made that ISO 3691-4 clause 5.2.3 universally mandates dual-channel SBC (S1, S15, S24).
Case E: what the checker leaves for validation
For the illustrative 1,600 kg vehicle at 1.2 m/s, translational kinetic energy is ½ × 1,600 × 1.2² = 1,152 J. This is one energy component, not a braking-resistor rating: add rotating inertia and downhill potential energy, then account for losses, battery absorption, stop frequency and the drive’s peak/continuous shunt limits (S25). Case E below calculates traction with equal wheel sharing only. Obtain DC input-current traces, brake data and stopping tests from the supplier before choosing the BMS, fuse or resistor.
AGV Motor Technology Selection Matrix
Qualitative procurement comparison, not certified performance. Ripple, efficiency class, lifetime and cleanroom suitability remain unknown without model-specific evidence. Sources: S10, S16, S23; application checks are engineering judgment.
| Motor Technology | Commutation & Waveform | Torque Ripple | Efficiency Class | Odometry & SLAM | Maintenance | Cleanroom (ISO 14644) | Application Fit |
|---|---|---|---|---|---|---|---|
| PM brushless motor with sinusoidal / FOC drive | Match winding back-EMF, current waveform and feedback (S16) | Potentially smoother than six-step; request measured ripple at the required speed and load | Unknown until tested; PMSM / BLDC naming does not assign an IE class (S23) | Validate wheel-speed error, encoder resolution and slip together; no SLAM guarantee | No brush wear; bearing, seal and gearbox service intervals require supplier evidence (S10) | Unknown; request application-specific particle testing, lubricant and enclosure evidence | Candidate for creep-speed traction when control cost and commissioning are justified |
| PM brushless motor with six-step drive | Electronic block commutation; Hall feedback is one option (S16) | Commutation ripple depends on motor and controller; no universal percentage (S16) | Unknown; compare measured motor-plus-drive efficiency at matched operating points | Test low-speed velocity stability on the actual vehicle | No brush wear; bearing and drivetrain maintenance remain (S10) | Unknown; absence of brush dust does not certify a cleanroom class | Candidate where simpler control meets measured speed, noise and vibration requirements |
| Brushed DC | Mechanical commutator and brushes; commonly PWM driven | Depends on construction, load and control; request measurements | Unknown; no IE class inferred from construction | Requires appropriate feedback and EMI checks for the chosen controller | Brush and commutator wear require a supplier maintenance plan (S10) | Brush debris is a contamination concern; assess containment and particle limits | Legacy retrofit candidate; budget brush access, replacement labor and downtime |
| Closed-loop hybrid stepper | Stepped / microstepped phase-current control with feedback | Check resonance and the torque-speed curve with the selected drive | Unknown; holding-current reduction and cooling depend on drive configuration | Feedback helps detect following errors; it does not measure wheel slip | No brushes; verify bearing life and installed temperature | Unknown; requires assembly-level particle and lubricant evidence | Consider for positioning or steering; verify traction speed and thermal demand separately |
| AC induction with variable-speed drive | Inverter-fed AC; scalar or vector control according to requirements | Depends on machine, inverter and tuning; request matched-load data | Unknown; confirm the applicable standard and measured efficiency map (S23) | Assess feedback and low-speed control under actual load | No brushes or permanent magnets; insulation, bearings and cooling still limit life | Unknown; enclosure rating alone does not establish particle cleanliness | Compare available voltage, packaging and installed thermal performance with PM alternatives |
Multi-Motor Drivetrain Kinematic Configurations
Illustrative layout trade-offs and validation questions, not standards-derived payload or suspension limits. Motor counts describe the shown configuration; measure actual DC inputs.
| Layout Architecture | Motor Count (Traction + Steer) | Degrees of Freedom | Scrub Torque | Suspension Requirement | DC Bus Load Check | Payload & Application Fit |
|---|---|---|---|---|---|---|
| Dual-wheel differential drive | 2 traction motors; passive support-wheel count varies | Forward speed and yaw rate; cannot command instantaneous lateral translation | Check caster swivel resistance, tire contact patches and any fixed support-wheel scrub | Maintain drive-wheel normal load over route unevenness; suspension travel is vehicle-specific | Sum simultaneous DC input currents of both drives and auxiliaries | Warehouse AMRs and tuggers; payload depends on axle loads, traction and ratings |
| 4-wheel Mecanum | 4 independently controlled traction motors in this example | Forward, lateral and yaw commands under ideal roller-contact conditions | Roller losses and lateral traction require route measurements; no fixed energy penalty | Maintain roller contact with compliance or load equalization; no universal floor-flatness class | Sum actual simultaneous drive inputs; individual loads differ by maneuver | Lateral docking and confined routes; verify wheel loads and floor compatibility |
| Single steered traction wheel | 1 traction + 1 steering motor; support layout varies | Steering-constrained motion; lateral translation depends on support-wheel geometry | Rolling turns may reduce scrub; stationary steering can still demand high torque | Three-point support can help contact; still verify axle loading on ramps | Include traction and steering peaks when they overlap, plus auxiliaries | Pallet trucks and tuggers; no payload range follows from layout alone |
| Dual steered traction wheels | 2 traction + 2 steering motors | Crab and yaw capability depend on support geometry and steering range | Align wheel axes to the turn center; angle errors and stationary steering create scrub | Verify contact and load equalization; no single suspension arrangement is required | Sum each traction and steering DC input; motor count is not a current multiplier | Flexible industrial transport; coordinate steering and traction before release |
| Four steered modules / swerve | 4 traction + 4 steering motors in this example | Planar translation and yaw after wheel-angle alignment; steering transients constrain motion | Ideal alignment reduces scrub; compliance and steering errors remain | Verify all-wheel contact and load equalization across route transitions | Measure the concurrent eight-axis load and regenerative envelope | Agile platforms; more drives, wiring and commissioning increase cost and fault-handling work |
Multi-Axis Bus Synchronization & Fieldbus Protocols
Vendor-document checklist, not a timing or safety ranking. S19 supports CiA 402 behavior and device-variation limits; the other interfaces require the selected vendor’s documentation. Timing remains unknown until configuration and measurement.
| Fieldbus Protocol | Sync Mechanism | Cycle Time & Jitter | Multi-Axis Addressing | Safety Protocol | Trajectory Suitability |
|---|---|---|---|---|---|
| CANopen / CiA 402 | Verify supported modes, PDO timing and SYNC behavior in the exact drive manual (S19) | Unknown until bus load, node count and master scheduling are specified and measured | Verify the EDS / object dictionary; do not assume an Axis 2 offset or node topology | Standard motion PDOs do not establish a safety function; verify any separate certified safety path | Candidate when measured timing, fault response and supported operating modes meet the vehicle requirements |
| EtherCAT / CoE | Verify drive-supported clock synchronization and CiA 402 mode mapping | Unknown for the selected system; distinguish clock alignment from end-to-end command latency | Confirm ESI, axis mapping and process data with the drive vendor | Verify any FSoE option and certification separately; ordinary EtherCAT is not a safety approval | Compare measured timing and commissioning effort with the existing controller stack |
| PROFINET / PROFIdrive | Verify that the controller and drive both support the requested RT / IRT mode | Unknown until the supported mode, topology and configured cycle are confirmed | Verify device description and configured module / axis mapping | Confirm any PROFIsafe option and complete safety-function validation separately | Consider where the selected vehicle controller already supports this interface |
| Modbus RTU / RS-485 | Sequential request-response polling; account for baud rate, message count and retries | Unknown until a worst-case polling schedule is calculated and tested | Vendor register map and configured node addresses | Ordinary Modbus RTU messages do not establish a validated safety stop | Use only if tested update latency and fault behavior meet the task; no synchronized-motion guarantee |
Scenario examples with assumptions and outcomes
Scenarios reuse the same tool model to keep recommendation logic consistent across cases.
AGV motor sizing FAQ
Answers cover inputs, calculation limits, supplier checks, and next steps.
Related AGV motor engineering resources
Continue with drivetrain architecture checks, integration references, and direct technical RFQ actions.
- AGV Motor Suppliers Matrix & Sourcing Guide
- AGV Motor Factory Sourcing Evaluator
- AGV Motor China Sourcing Cost Checker
- AGV Motor Wheel & Motorized Steering Wheel Sizing
- Forklift AGV drive wheel integration reference
- Differential drive checker for route architecture
- AGV and AMR Adoption in Factories
- Commercial Service AGV Drive Wheel Checker
- Request custom AGV motor engineering review
- AGV Forklift Steering Wheel Drive Validation Tool
Need a supplier to confirm the motor fit?
Share the mission assumptions and screening result for a review against supplier ratings and vehicle-level validation data.